



Arduino Mega : Capturer des photos et les téléverser automatiquement sur Google Drive
Composants et fournitures
| Arduino Mega 2560 | × | 1 |
| PHPoC WiFi Shield 2 pour Arduino | × | 1 |
| Seeed Grove - Kit caméra série | × | 1 |
| Seeed Grove base shield | × | 1 |
| Bouton | × | 1 |
À propos de ce projet
Si vous êtes débutant, vous pouvez apprendre l'Arduino ici.
Démonstration
Comment ça marche
1. Se connecter au compte Google via OAuth 2.0 pour appareils IoT pour obtenir access_token.
Le processus de connexion est décrit dans ce projet sur Hackster.
2. Lorsque le bouton est pressé, l'Arduino récupère l'image de la caméra, puis la téléverse sur Google Drive en utilisant access_token via l'API Google Drive.
L'API Google Drive pour le téléversement de fichier est décrite dans la documentation Google.
Comment faire
- Créer un projet Google depuis le portail Google Developer et obtenir GOOGLE_CLIENT_ID et GOOGLE_CLIENT_SECRET
- Remplacer GOOGLE_CLIENT_ID et GOOGLE_CLIENT_SECRET dans le code Arduino
- Téléverser le fichier login.php sur le PHPoC Shield. Voir les instructions
- Compiler et téléverser le code Arduino via l'IDE Arduino
- Voir l'adresse IP du shield PHPoC sur le moniteur série
- Accéder à la page de connexion sur le PHPoC Shield : https://adresse_ip/login.php et se connecter à votre compte Google
- Appuyer sur le bouton pour prendre une photo
- Vérifier votre Google Drive après deux secondes, vous verrez la photo prise dans votre Drive.
Autre plateforme matérielle
J'ai réalisé le même projet pour une autre plateforme matérielle ici.
Le meilleur kit de démarrage Arduino pour débutant
Si vous cherchez un kit Arduino, voir Le meilleur kit Arduino pour débutants
Références de fonctions
- Serial.begin()
- Serial.println()
- delay()
- millis()
- boucle for
- boucle while
- if else
- loop()
- setup()
- String.toInt()
- String.substring()
- String.indexOf()
- String.remove()
- String.equals()
Code
- ArduinoGoogleDrive
- login.php
- grove_camera.h
ArduinoGoogleDrive (Arduino)
Ceci est le code principal Arduino.
#include <Phpoc.h>
#include <Arduino_JSON.h>
#include "grove_camera.h"

// Remplacer votre GOOGLE_CLIENT_ID et GOOGLE_CLIENT_SECRET ici
String GOOGLE_CLIENT_ID = "xxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxxx.apps.googleusercontent.com";
String GOOGLE_CLIENT_SECRET = "xxxxxxxxxxxxxxxxxxxxxxxx";

PhpocServer websocket_server(80);

String http_resp_hearder(PhpocClient &client) {
  String hearder = "";
  while(1) {
    if(client.available()) {
      String line = client.readLine();
      if(line == "\r\n") break;
      else hearder += line;
    }
    if(!client.connected()) {
      client.stop();
      break;
    }
  }
  return hearder;
}

String http_resp_body(PhpocClient &client) {
  String body = "";
  while(1) {
    if(client.available()) {
      char c = client.read();
      body += c;
    }
    if(!client.connected()) {
      client.stop();
      break;
    }
  }
  return body;
}

String access_token = "";
String refresh_token = "";
unsigned long access_token_expire_at = 0;

void websocket_send(String msg) {
  char wbuf[256];
  msg.toCharArray(wbuf, msg.length() + 1);
  websocket_server.write(wbuf, msg.length());
}

void googleDeviceOAuthLogin() {
  PhpocClient client;
  // Étape 1: Demander les codes appareil et utilisateur
  if(client.connectSSL("accounts.google.com", 443)) {
    Serial.println(F("Connected to server"));
    String body = F("client_id=");
    body += GOOGLE_CLIENT_ID;
    body += F("&scope=https://www.googleapis.com/auth/drive.file");
    client.println(F("POST /o/oauth2/device/code HTTP/1.1"));
    client.println(F("Host: accounts.google.com"));
    client.println(F("Connection: close"));
    client.println(F("Accept: */*"));
    client.println(F("Content-Type: application/x-www-form-urlencoded"));
    client.print(F("Content-Length: "));
    client.println(body.length());
    client.println();
    client.print(body);
    String response_hearder = http_resp_hearder(client);
    String response_body = http_resp_body(client);
    //Serial.println(response_hearder);
    //Serial.println(response_body);
    JSONVar body_json = JSON.parse(response_body);
    if(JSON.typeof(body_json) == "undefined") {
      Serial.println("Parsing input failed!");
      return;
    }
    // Étape 2: Gérer la réponse du serveur d'autorisation
    String device_code = "";
    String user_code = "";
    long expires_in = 0;
    int interval = 0;
    String verification_url = "";
    bool is_valid = true;
    if(body_json.hasOwnProperty("device_code")) device_code = body_json["device_code"];
    else is_valid = false;
    if(body_json.hasOwnProperty("user_code")) user_code = body_json["user_code"];
    else is_valid = false;
    if(body_json.hasOwnProperty("expires_in")) expires_in = (long) body_json["expires_in"];
    else is_valid = false;
    if(body_json.hasOwnProperty("interval")) interval = (int) body_json["interval"];
    else is_valid = false;
    if(body_json.hasOwnProperty("verification_url")) verification_url = body_json["verification_url"];
    else is_valid = false;
    if(is_valid) {
      // Étape 3: Afficher le code utilisateur
      Serial.print(F("Next, visit "));
      Serial.print(verification_url);
      Serial.print(F(" on your desktop or smartphone and enter this code: "));
      Serial.println(user_code);
      String msg;
      msg = "{\"provider\": \"google\",";
      msg += "\"action\": \"LOGIN\",";
      msg += "\"verification_url\": \"" + verification_url + "\",";
      msg += "\"user_code\": \"" + user_code + "\"}";
      websocket_send(msg);
      // Étape 5: Interroger le serveur d'autorisation
      int poll_max = expires_in / interval;
      body = F("client_id=");
      body += GOOGLE_CLIENT_ID;
      body += F("&client_secret=");
      body += GOOGLE_CLIENT_SECRET;
      body += F("&code=");
      body += device_code;
      body += F("&grant_type=https://oauth.net/grant_type/device/1.0");
      for(int poll_count = 0; poll_count < poll_max; poll_count++) {
        if(client.connectSSL("www.googleapis.com", 443)) {
          client.println(F("POST /oauth2/v4/token HTTP/1.1"));
          client.println(F("Host: www.googleapis.com"));
          client.println(F("Connection: close"));
          client.println(F("Accept: */*"));
          client.println(F("Content-Type: application/x-www-form-urlencoded"));
          client.print(F("Content-Length: "));
          client.println(body.length());
          client.println();
          client.print(body);
          response_hearder = http_resp_hearder(client);
          response_body = http_resp_body(client);
          //Serial.println(response_hearder);
          //Serial.println(response_body);
          body_json = JSON.parse(response_body);
          if(JSON.typeof(body_json) == "undefined") {
            Serial.println("Parsing input failed!");
            return;
          }
          long token_expires_in = 0;
          bool is_authorized = true;
          if(body_json.hasOwnProperty("access_token")) access_token = body_json["access_token"];
          else is_authorized = false;
          if(body_json.hasOwnProperty("expires_in")) token_expires_in = (long) body_json["expires_in"];
          else is_authorized = false;
          if(body_json.hasOwnProperty("refresh_token")) refresh_token = body_json["refresh_token"];
          else is_authorized = false;
          if(is_authorized) {
            access_token_expire_at = millis() + token_expires_in * 1000;
            //Serial.print("access_token:");
            //Serial.println(access_token);
            // envoyer message de succès au web
            msg = "{\"provider\": \"google\",";
            msg += "\"action\": \"SUCCESS\"}";
            websocket_send(msg);
            break;
          }
        }
        delay(interval * 1000);
      }
    } else Serial.println(F("Invalid resonse from Google"));
  } else Serial.println(F("NOT Connected to server"));
}

void cameraToGoogleDrive() {
  if(access_token == "") {
    Serial.println(F("access_token is invalid"));
    return;
  }
  long picture_len = cameraGetPicture();
  if(picture_len) {
    PhpocDateTime datetime;
    PhpocClient client;
    String file_name;
    String metadata;
    String jpeg_boundary;
    String end_boundary;
    datetime.date(F("YmdHis"));
    file_name = datetime.date();
    metadata = F("--foo_bar_baz\r\n");
    metadata += F("Content-Type: application/json; charset=UTF-8\r\n\r\n");
    metadata += "{\"title\": \"ARDUINO_" + file_name + "\"}\r\n\r\n";
    jpeg_boundary = F("--foo_bar_baz\r\n");
    jpeg_boundary += F("Content-Type: image/jpeg\r\n\r\n");
    end_boundary = F("\r\n--foo_bar_baz--");
    unsigned long body_len = metadata.length() + jpeg_boundary.length() + picture_len + end_boundary.length();
    int total = 0;
    if(client.connectSSL("www.googleapis.com", 443)) {
      Serial.println(F("Connected to server"));
      String body = F("client_id=");
      body += GOOGLE_CLIENT_ID;
      body += F("&scope=https://www.googleapis.com/auth/drive.file");
      client.println(F("POST /upload/drive/v2/files?uploadType=multipart HTTP/1.1"));
      client.println(F("Host: www.googleapis.com"));
      client.println(F("Connection: close"));
      client.println(F("Accept: */*"));
      client.println(F("Content-Type: multipart/related; boundary=foo_bar_baz"));
      client.print(F("Content-Length: "));
      client.println(body_len);
      client.print(F("Authorization: Bearer "));
      client.println(access_token);
      client.println();
      client.print(metadata);
      client.print(jpeg_boundary);
      int i;
      int packet_num = cameraPacketNum();
      char packet[PIC_PKT_LEN] = {0};
      for(i = 0; i < packet_num; i++) {
        long packet_len = cameraGetPacket(i, packet);
        client.write((const uint8_t *)&packet[4], packet_len - 6);
        total += packet_len - 6;
      }
      cameraGetPacket(i, packet);
      client.print(end_boundary);
      String response_hearder = http_resp_hearder(client);
      String response_body = http_resp_body(client);
      //Serial.println(response_hearder);
      Serial.println(response_body);
    }
  } else {
    Serial.print("picture_len:");
    Serial.println(picture_len);
  }
}

int buttonState;
int lastButtonState = LOW;
unsigned long lastDebounceTime = 0;
unsigned long debounceDelay = 50;

bool isButtonPressed(int pin) {
  int reading = digitalRead(pin);
  if (reading != lastButtonState) lastDebounceTime = millis();
  if ((millis() - lastDebounceTime) > debounceDelay) {
    if (reading != buttonState) {
      buttonState = reading;
      if (buttonState == HIGH) {
        return true;
      }
    }
  }
  lastButtonState = reading;
  return false;
}

void setup() {
  Serial.begin(115200);
  while(!Serial) ;
  Phpoc.begin(PF_LOG_SPI | PF_LOG_NET);
  websocket_server.beginWebSocket("login");
  Serial.print("WebSocket server address: ");
  Serial.println(Phpoc.localIP());
  pinMode(2, INPUT);
  cameraInit(CT_JPEG, PR_160x120, JR_640x480);
}

void loop() {
  PhpocClient client = websocket_server.available();
  if (client) {
    String ws_str = client.readLine();
    if(ws_str == "google\r\n") {
      googleDeviceOAuthLogin();
    }
  }
  if(isButtonPressed(2)) {
    if(access_token != "" && access_token_expire_at > millis())
      cameraToGoogleDrive();
    else
      Serial.println("access_token is invalid, please login again");
  }
}
login.php (PHP)
Ce code est téléversé sur le PHPoC Shield. Il fournit une interface utilisateur web pour le processus de connexion Google.
<html>
<head>
<title>PHPoC / <?echo system("uname -i")?></title>
<meta content="initial-scale=1.0, maximum-scale=1.0, minimum-scale=0.5, width=device-width, user-scalable=yes" name="viewport">
<link rel="stylesheet" href="https://fonts.googleapis.com/css?family=Roboto" type="text/css">
<style>
body { text-align:center; }
.center { margin: auto; position: absolute; -webkit-backface-visibility: hidden; left:0; right:0; text-align: center; top: 20%; }
.hearder { width: 100%; max-width:400px; color: #008B8B; padding: 5px; border-bottom: solid; margin-bottom: 5px; font-size: 200%; display: inline-block; }
.wc_text, .loader { display: inline-block; width: 100%; max-width:300px; line-height: 150%; }
.code { font-family: "Courier New", Courier, monospace; font-size: 150%; font-weight: bold; color: #A52A2A; }
.success {font-weight: bold; color: #A52A2A;}

/*icône de chargement*/
.lds-roller { display: inline-block; position: relative; width: 64px; height: 64px; }
.lds-roller div { animation: lds-roller 1.2s cubic-bezier(0.5, 0, 0.5, 1) infinite; transform-origin: 32px 32px; }
.lds-roller div:after { content: " "; display: block; position: absolute; width: 6px; height: 6px; border-radius: 50%; background: #A52A2A; margin: -3px 0 0 -3px; }
.lds-roller div:nth-child(1) {animation-delay: -0.036s;}
.lds-roller div:nth-child(1):after {top: 50px;left: 50px;}
.lds-roller div:nth-child(2) {animation-delay: -0.072s;}
.lds-roller div:nth-child(2):after {top: 54px;left: 45px;}
.lds-roller div:nth-child(3) {animation-delay: -0.108s;}
.lds-roller div:nth-child(3):after {top: 57px;left: 39px;}
.lds-roller div:nth-child(4) {animation-delay: -0.144s;}
.lds-roller div:nth-child(4):after {top: 58px;left: 32px;}
.lds-roller div:nth-child(5) {animation-delay: -0.18s;}
.lds-roller div:nth-child(5):after {top: 57px;left: 25px;}
.lds-roller div:nth-child(6) {animation-delay: -0.216s;}
.lds-roller div:nth-child(6):after {top: 54px;left: 19px;}
.lds-roller div:nth-child(7) {animation-delay: -0.252s;}
.lds-roller div:nth-child(7):after {top: 50px;left: 14px;}
.lds-roller div:nth-child(8) {animation-delay: -0.288s;}
.lds-roller div:nth-child(8):after {top: 45px;left: 10px;}
@keyframes lds-roller {0% {transform: rotate(0deg);}100% {transform: rotate(360deg);}}
</style>
<script>
var ws;
function init() {
  ws = new WebSocket("ws://<?echo _SERVER("HTTP_HOST")?>/login", "text.phpoc");
  ws.onopen = ws_onopen;
  ws.onclose = ws_onclose;
  ws.onmessage = ws_onmessage;
}
function ws_onopen() {
  if(ws && (ws.readyState == 1)) ws.send('google\r\n');
}
function ws_onclose() {
  alert('CANNOT connect to device. Please reload webpage');
  ws.onopen = null;
  ws.onclose = null;
  ws.onmessage = null;
  ws = null;
}
function ws_onmessage(e_msg) {
  e_msg = e_msg || window.event; // MessageEvent
  var obj = JSON.parse(e_msg.data);
  var wc_text = document.getElementById('wc_text');
  if(obj.action == 'LOGIN') {
    wc_text.innerHTML = 'Next, visit <a href="' + obj.verification_url + '" target="_blank">' + obj.verification_url + '</a> and enter this code:<br>';
    wc_text.innerHTML += '<span class="code">' + obj.user_code + '</span>';
  } else if(obj.action == 'SUCCESS') {
    document.getElementById('loader').style.display = 'none';
    wc_text.innerHTML = '<span class="success">Success!</span><br>';
    wc_text.innerHTML += 'You are now logged in from Arduino via PHPoC Shield';
  }
}
window.onload = init;
</script>
</head>
<body>
<div class="center">
<div class="hearder">
<div style="font-size: 150%">
<span style="color:#4285F4">G</span>
<span style="color:#EA4335;">o</span>
<span style="color:#FBBC05;">o</span>
<span style="color:#4285F4;">g</span>
<span style="color:#34A853;">l</span>
<span style="color:#EA4335;">e</span>
</div>
Login for Arduino
</div>
<br><br>
<div class="wc_text" id="wc_text"></div><br><br>
<div class="loader" id="loader">
<div class="lds-roller"><div></div><div></div><div></div><div></div><div></div><div></div><div></div><div></div></div>
</div>
</div>
</body>
</html>
grove_camera.h (C/C++)
Bibliothèque pour caméra Grove
#define PIC_PKT_LEN 512 // longueur de données de chaque lecture, ne pas trop grand car RAM limitée
#define CAM_ADDR 0 // Type de couleur
#define CT_GRAYSCALE_2 0x01
#define CT_GRAYSCALE_4 0x02
#define CT_GRAYSCALE_8 0x03
#define CT_COLOR_12 0x05
#define CT_COLOR_16 0x06
#define CT_JPEG 0x07
// Résolution d'aperçu
#define PR_80x60 0x01
#define PR_160x120 0x03
// Résolution JPEG
#define JR_80x64 0x01
#define JR_160x128 0x03
#define JR_320x240 0x05
#define JR_640x480 0x07

const byte camera_address = (CAM_ADDR << 5); // adresse
unsigned int camera_packet_num;
unsigned int camera_last_packet_len;

void cameraClearRxBuf() {
  while (Serial.available()) {
    Serial.read();
  }
}

void cameraSendCmd(char cmd[], int cmd_len) {
  for (char i = 0; i < cmd_len; i++) Serial.print(cmd[i]);
}

unsigned int cameraPacketNum() {
  return camera_packet_num;
}

void cameraInit(int color_type, int preview_resolution, int jpeg_resolution) {
  char cmd[] = {0xaa,0x0d|camera_address,0x00,0x00,0x00,0x00};
  unsigned char resp[6];
  Serial.setTimeout(500);
  while (1) {
    cameraSendCmd(cmd,6);
    if(Serial.readBytes((char *)resp, 6) != 6) continue;
    if(resp[0] == 0xaa && resp[1] == (0x0e | camera_address) && resp[2] == 0x0d && resp[4] == 0 && resp[5] == 0) {
      if(Serial.readBytes((char *)resp, 6) != 6) continue;
      if(resp[0] == 0xaa && resp[1] == (0x0d | camera_address) && resp[2] == 0 && resp[3] == 0 && resp[4] == 0 && resp[5] == 0) break;
    }
  }
  cmd[1] = 0x0e | camera_address;
  cmd[2] = 0x0d;
  cameraSendCmd(cmd, 6);
  char cmd2[] = { 0xaa, 0x01 | camera_address, 0x00, color_type, preview_resolution, jpeg_resolution};
  Serial.setTimeout(100);
  while (1) {
    cameraClearRxBuf();
    cameraSendCmd(cmd2, 6);
    if(Serial.readBytes((char *)resp, 6) != 6) continue;
    if(resp[0] == 0xaa && resp[1] == (0x0e | camera_address) && resp[2] == 0x01 && resp[4] == 0 && resp[5] == 0) break;
  }
  char cmd3[] = { 0xaa, 0x06 | camera_address, 0x08, PIC_PKT_LEN & 0xff, (PIC_PKT_LEN>>8) & 0xff ,0};
  while (1) {
    cameraClearRxBuf();
    cameraSendCmd(cmd3, 6);
    if(Serial.readBytes((char *)resp, 6) != 6) continue.
    if(resp[0] == 0xaa && resp[1] == (0x0e | camera_address) && resp[2] == 0x06 && resp[4] == 0 && resp[5] == 0) break;
  }
}

long cameraGetPicture() {
  char cmd[] = { 0xaa, 0x04 | camera_address, 0x01, 0x00, 0x00, 0x00 };
  unsigned char resp[6];
  unsigned long picTotalLen = 0; // longueur image
  while (1) {
    cameraClearRxBuf();
    cameraSendCmd(cmd, 6);
    if(Serial.readBytes((char *)resp, 6) != 6) continue;
    if(resp[0] == 0xaa && resp[1] == (0x0e | camera_address) && resp[2] == 0x04 && resp[4] == 0 && resp[5] == 0) {
      Serial.setTimeout(1000);
      if(Serial.readBytes((char *)resp, 6) != 6) continue;
      if(resp[0] == 0xaa && resp[1] == (0x0a | camera_address) && resp[2] == 0x01) {
        picTotalLen = (resp[3]) | (resp[4] << 8) | (resp[5] << 16);
        break;
      }
    }
  }
  camera_packet_num = (picTotalLen) / (PIC_PKT_LEN - 6);
  camera_last_packet_len = PIC_PKT_LEN;
  if((picTotalLen % (PIC_PKT_LEN-6)) != 0) {
    camera_packet_num += 1;
    camera_last_packet_len = picTotalLen % (PIC_PKT_LEN - 6) + 6;
  }
  return picTotalLen;
}

long cameraGetPacket(unsigned int i, char* buf) {
  char cmd[] = { 0xaa, 0x0e | camera_address, 0x00, 0x00, 0x00, 0x00 };
  Serial.setTimeout(100);
  if(i < camera_packet_num) {
    cmd[4] = i & 0xff;
    cmd[5] = (i >> 8) & 0xff;
    cameraClearRxBuf();
    cameraSendCmd(cmd, 6);
    int pkt_len;
    if(i < (camera_packet_num - 1)) pkt_len = PIC_PKT_LEN;
    else pkt_len = camera_last_packet_len;
    uint16_t cnt = Serial.readBytes((char *)buf, pkt_len);
    return cnt;
  } else {
    cmd[4] = 0xf0;
    cmd[5] = 0xf0;
    cameraSendCmd(cmd, 6);
  }
  return "";
}
Schémas
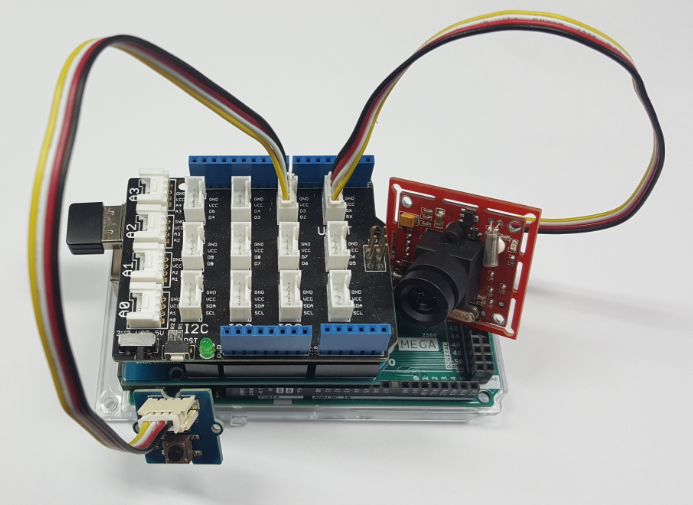
Processus de fabrication
- Construire un Spybot Arduino piloté par Bluetooth
- FlickMote : Télécommande IR à gestes pour maison connectée
- TV-B-Gone DIY Arduino : Télécommande universelle pour toutes les TV
- Construire une horloge maître LED personnalisée avec alarme – Visible à 12 mètres
- Find Me : Localisateur d'objets intelligent avec Arduino et Bluetooth
- Solutions d'alimentation optimisées pour projets Arduino
- Morpion sur matrice LED MAX7219 avec boîtier en carton
- Construire un robot quadrupède Arduino intelligent : guide étape par étape
- L'investissement de 450 M$ de Google dans ADT accélère l'adoption de la sécurité IoT